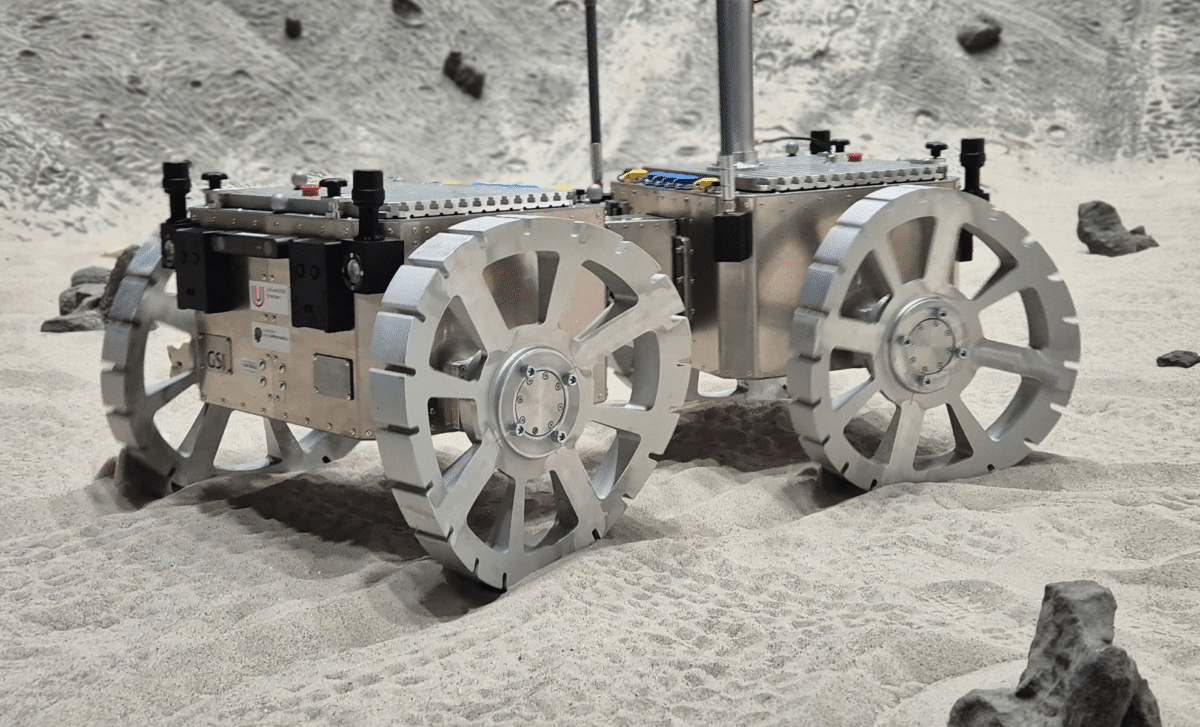
A new Mars rover design promises to change planetary exploration, using wheels modeled on the sandfish lizard to “swim” through soft sand rather than roll. Researchers at Universität Würzburg have translated a biological locomotion strategy into cutting-edge robotics, offering a glimpse at the next generation of adaptive planetary rovers.
Sandfish Lizard Inspires Next-Level Rover Mobility
Navigating the uneven, sandy terrain of Mars has always posed a major challenge for rover missions. Conventional wheels can easily slip, sink, or get stuck, limiting mission efficiency and risk management. “Conventional wheel designs are often optimized for driving at low speeds and tend to slip, sink or get stuck on soft ground,” says Amenosis Lopez, a researcher working with Professor Schmidt.
The team led by Marco Schmidt, Professor for Embedded Systems and Sensors for Earth Observation (ESSEO), drew inspiration from the sandfish lizard, a desert native capable of “swimming” beneath granular surfaces. This biological insight led to the creation of wheels that do not simply roll but emulate the lizard’s sinusoidal movement.
“The wheels mimic the animal’s characteristic interaction with the ground, generating both longitudinal and lateral forces. The rover leaves sinusoidal tracks in the sand—this confirms that the intended swimming mechanism has been achieved,” Schmidt explains.
Engineering Breakthrough: How Swimming Wheels Work
The innovative wheels depart from conventional designs by combining shape, flexibility, and motion patterns that distribute pressure more effectively on soft surfaces. Early tests showed that the wheels could traverse sand while maintaining stability, a problem that has historically hampered wheeled Mars rovers. Researchers carefully adjusted width and mass to reduce ground pressure and prevent sinking, while the wheel surface itself is being refined to improve traction on mixed terrain.
These developments are part of the VaMEx initiative under the German Aerospace Center, and the collaboration with the University of Bremen has been critical for testing in controlled sand fields and open terrain. By mimicking a natural adaptation honed over millennia, engineers have produced a solution that could make Martian exploration safer and more efficient.
Experimental Insights And Continuous Improvement
Extensive field experiments provided both validation and valuable lessons for future iterations. “The experiments also provided us with clear pointers for improvements,” says Schmidt. Initial designs were narrower and heavier than optimal, causing the rover to sink and reducing controllability. Adjustments to width and weight have since enhanced performance, demonstrating the importance of iterative prototyping in translating biological principles into robotics.
Beyond hardware, the team at Universität Würzburg aims to integrate software-controlled mobility, using real-time analysis of slippage, sinking, and terrain interaction. These intelligent control systems are expected to allow rovers to adapt dynamically to complex Martian surfaces, extending operational range and reducing mission risks.
Towards Intelligent, Adaptive Mars Rovers
The ultimate goal is to combine the physical innovation of swimming wheels with advanced software algorithms, creating a rover capable of autonomous navigation in unpredictable environments. By accounting for terrain interactions, slipping, and sinking, the system could adjust wheel motion and power distribution in real-time, mirroring the adaptability seen in desert-dwelling animals.
This breakthrough underscores the potential of bio-inspired design in space exploration, offering solutions that traditional engineering approaches struggle to achieve. As Mars missions expand in scope and ambition, the ability to traverse granular surfaces efficiently could be a defining factor in mission success.